

Ep#70: A Systematic Study of Data Modalities and Strategies for Co-training Large Behavior Models for Robot Manipulation
01 Apr 2026
1h 24m
Chris Paxton & Michael Cho geek out over robotic papers with paper authors. robopapers.substack.com
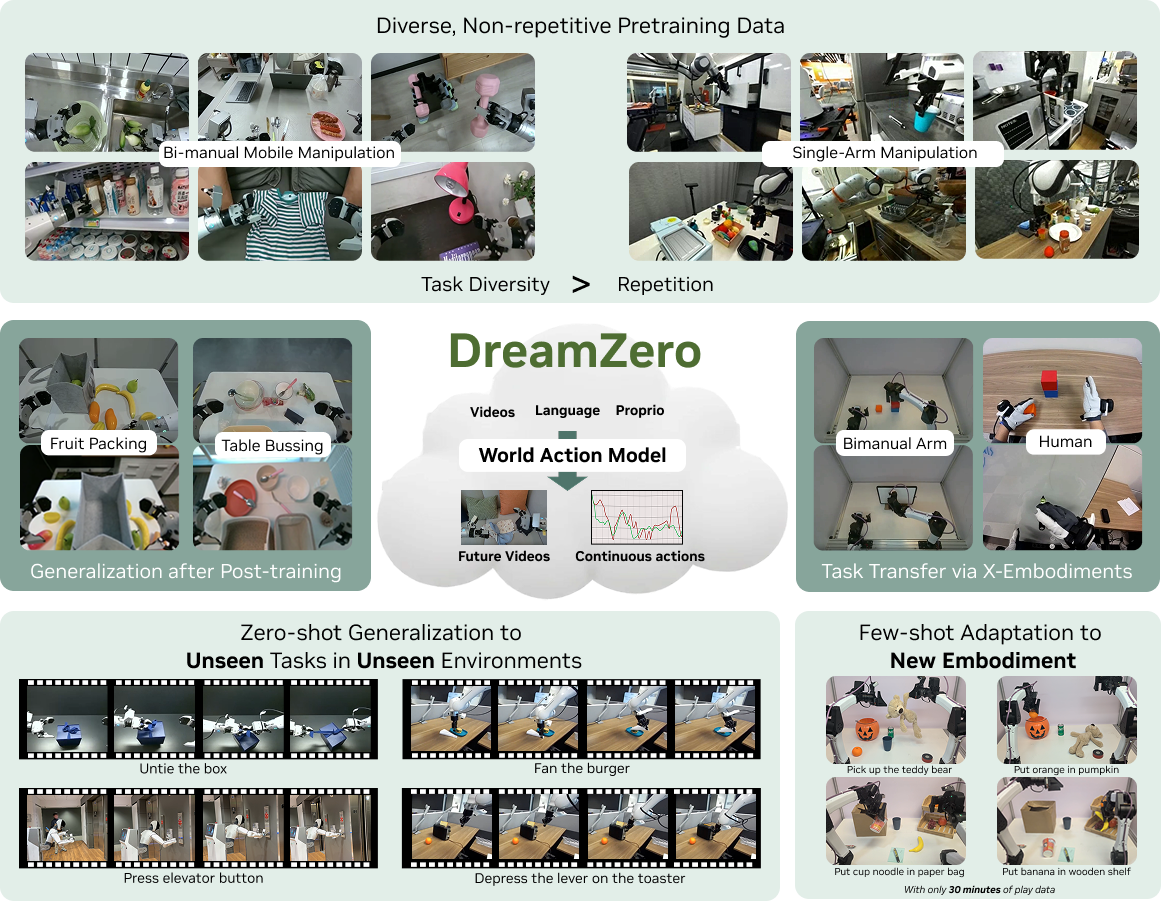
Evaluating robotic policies in the real world is notoriously difficult, slow, and non-reproducible, yet simulation benchmarks often fail to capture real-world performance accurately. A new approach addresses this by leveraging 3D Gaussian splatting and generative models to create scalable, low-cost simulation environme...
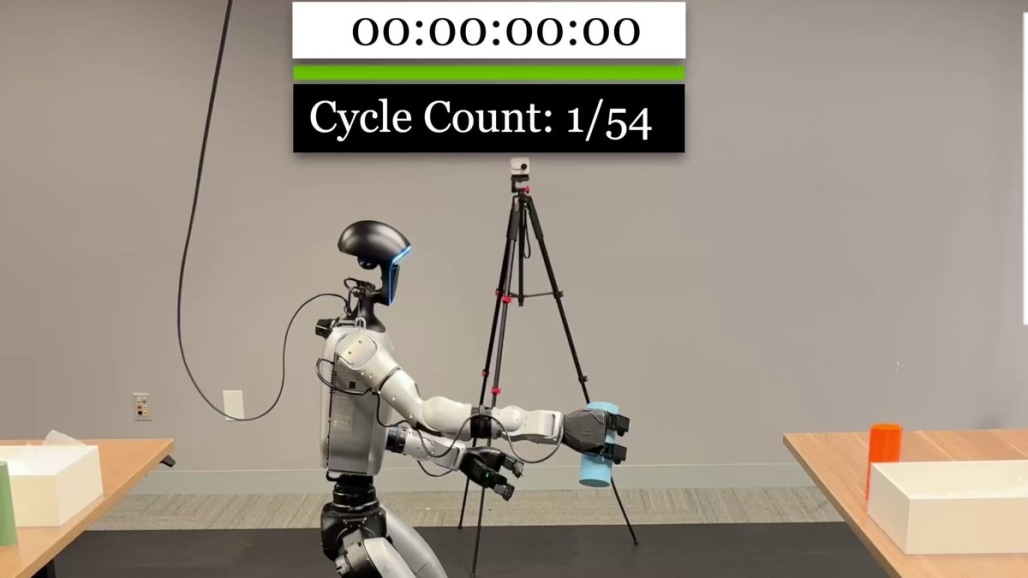
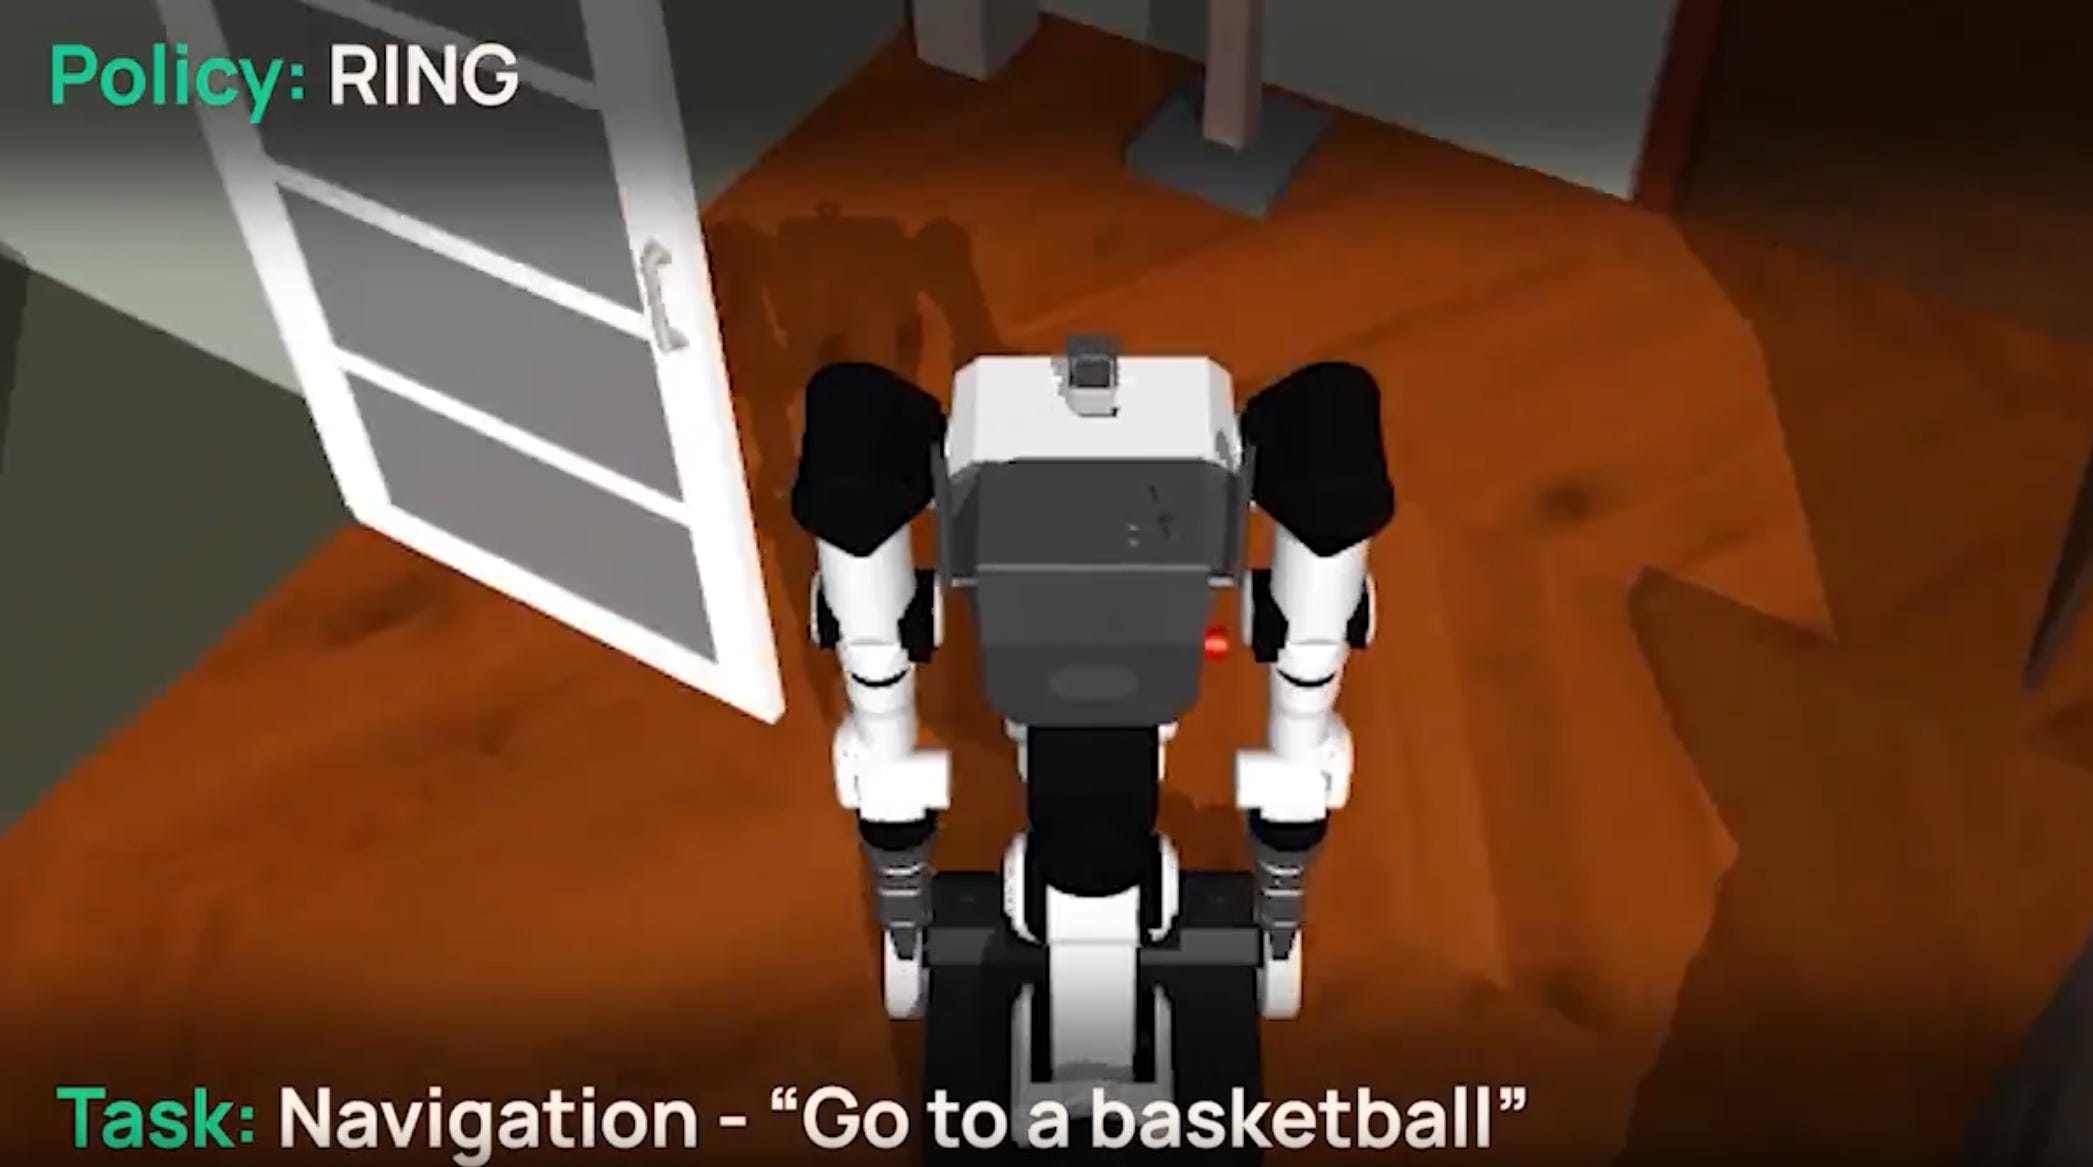
Humanoid loco-manipulation increasingly relies on sim-to-real reinforcement learning, yet bridging the gap between simulation and real-world deployment remains a significant challenge. The VIRAL and Doorman projects demonstrate that zero-shot, vision-based policy transfer is achievable for tasks like pick-and-place and...
Follow this podcast in Podwise
Sign in to get AI summaries, transcripts and mind maps for any episode, including new ones.