

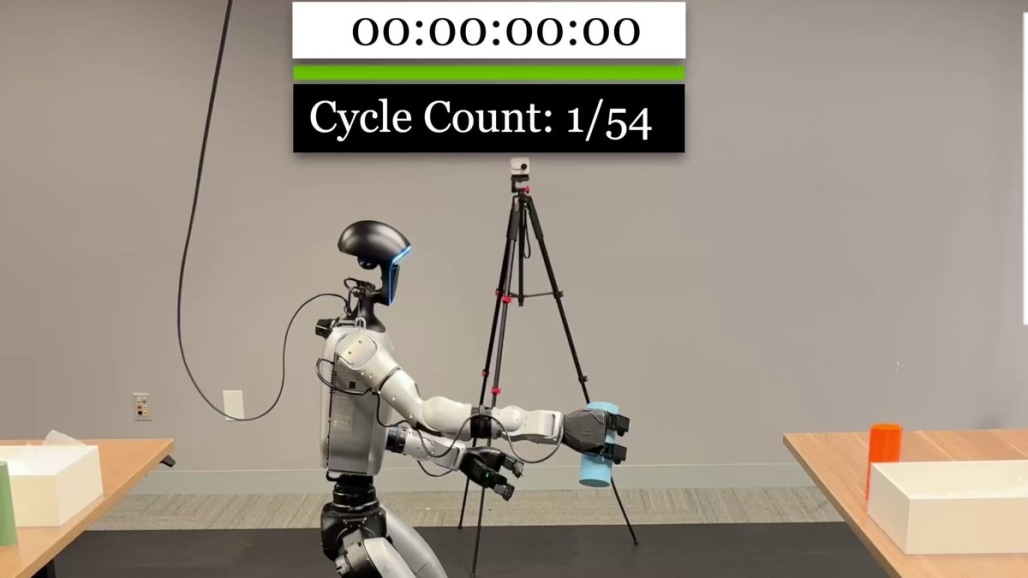
Humanoid loco-manipulation increasingly relies on sim-to-real reinforcement learning, yet bridging the gap between simulation and real-world deployment remains a significant challenge. The VIRAL and Doorman projects demonstrate that zero-shot, vision-based policy transfer is achievable for tasks like pick-and-place and door opening by utilizing teacher-student distillation frameworks and massive parallelization in Isaac Lab. Reward engineering serves as the primary bottleneck, necessitating multi-stage tuning and reference state initialization to drive stable, sim-to-real-friendly behavior. While visual randomization and compute scaling significantly enhance policy robustness, sim-to-real is not a universal solution. Complex contact dynamics and unmodeled real-world environments continue to limit the effectiveness of current simulation-based approaches. Future advancements likely require hybrid models that integrate large-scale human data with physical simulation to overcome the limitations of rigid-body modeling and manual reward design.
Sign in to continue reading, translating and more.
Open full episode in Podwise