

25 Nov 2025
1h 1m
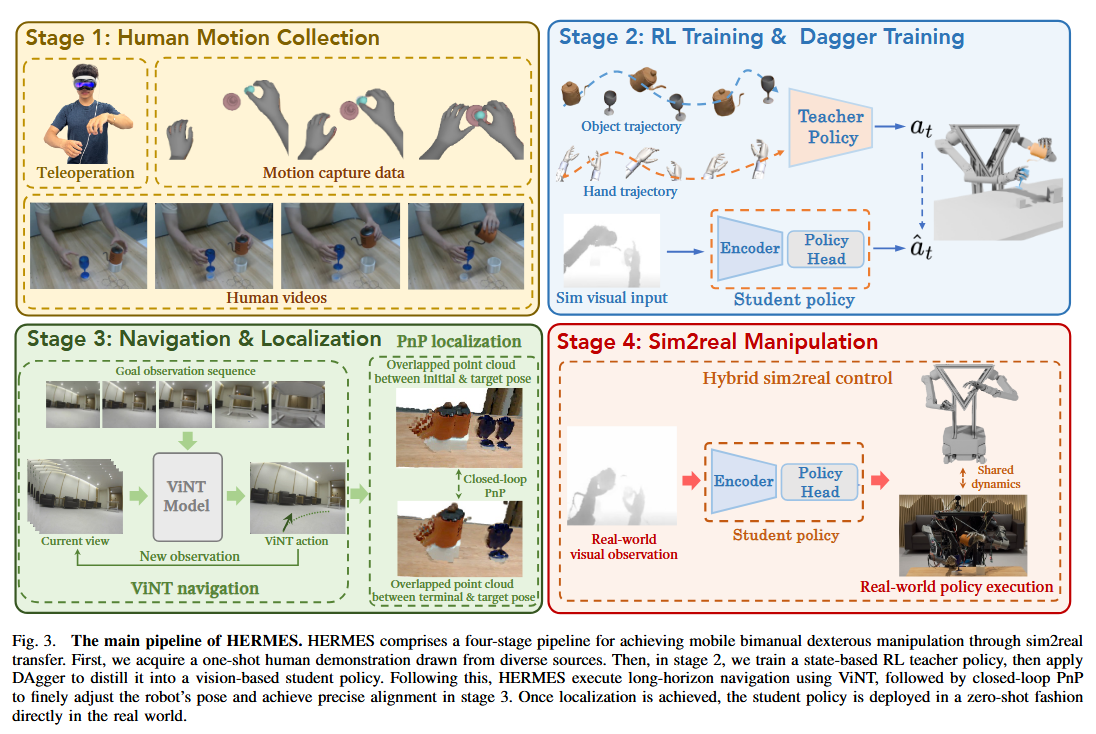
Ep#45: HERMES: Human-to-Robot Embodied Learning From Multi-Source Motion Data for Mobile Dexterous Manipulation
RoboPapers
Open in Podwise to generate AI notes
Sign in to process this episode and unlock summaries, transcripts, highlights and translations.
Shownotes are not generated by Podwise.