

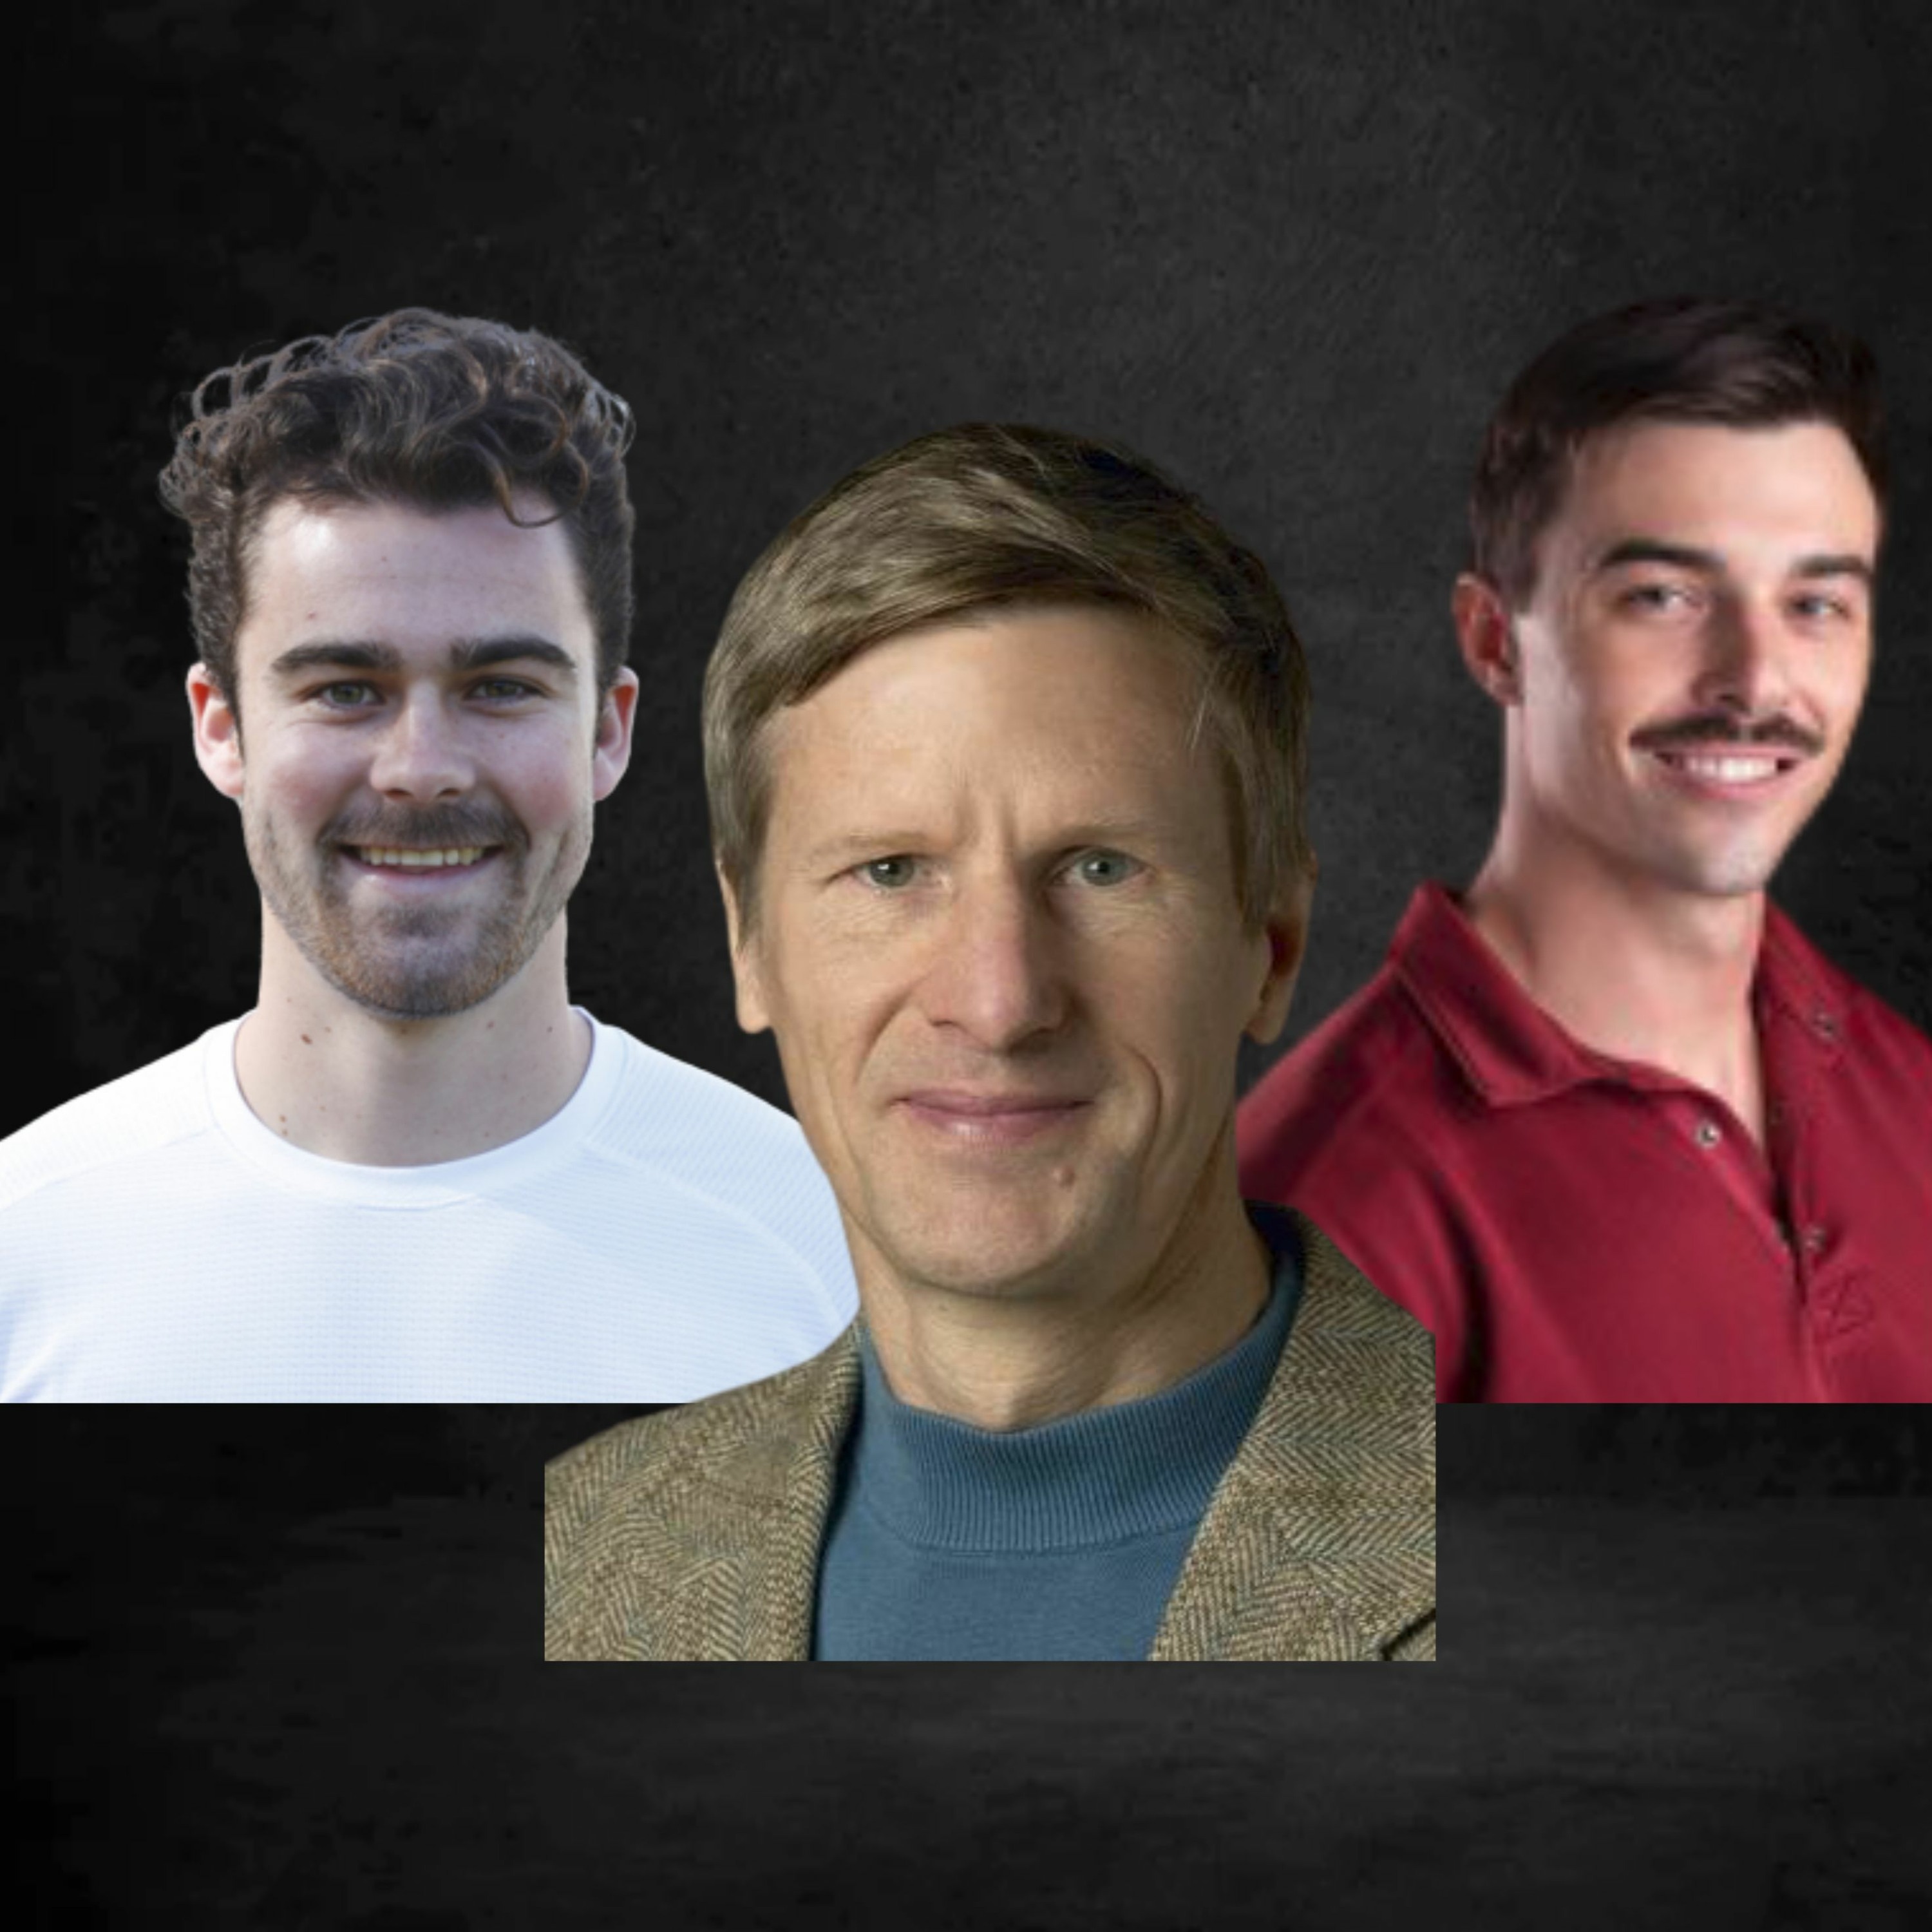
Mark Cutkosky, Wilson Ruotolo, Dane Brouwer "Robotic Hand With A Gecko-Like Grip"
Soft Robotics Podcast
Gecko-inspired adhesives offer a transformative approach to robotic grasping by prioritizing contact area over traditional normal force-based friction. By incorporating passive, ribbed structures behind these adhesives, robotic hands achieve uniform load sharing across complex object geometries without requiring high-level control. This design strategy addresses the limitations of rigid, tendon-driven systems, enabling more dexterous and gentle manipulation. While current prototypes demonstrate success in grasping diverse objects, challenges remain regarding adhesive performance on non-pristine surfaces and the need for integrated tactile sensing to improve force control. Advancements in fabrication, such as 3D printing and casting, allow for rapid iteration, bridging the gap between theoretical design and functional, anthropomorphic hardware. Future developments aim to enhance robustness and environmental adaptability, moving beyond simple pick-and-place tasks toward sophisticated, real-world robotic interaction.
Sign in to continue reading, translating and more.
Open full episode in Podwise